ROBOT LEARNING & REINFORCEMENT LEARNING

Sichang Su

Ph.D. student The University of Texas at Austin

Biography

I am a Ph.D. student in Aerospace Engineering at The University of Texas at Austin, advised by Dr. Fangzhou Xia.

My research interests lie in reinforcement learning and robotics. My recent work focuses on efficiently adapting robot foundation models to out-of-distribution tasks with minimal human supervision. My long-term goal is to enable robots to solve complex, diverse tasks efficiently in the real world.

I received my M.Sc. in Mechanical Engineering from the National University of Singapore, advised by Dr. Guillaume Adrien Sartoretti, and my B.Eng. in Engineering Mechanics from Zhejiang University.

EDUCATION

2025-present

The University of Texas at Austin

PhD in Aerospace Engineering

2023-2025

National University of Singapore

MSc in Mechanical Engineering

2019-2023

Zhejiang University

BEng in Engineering Mechanics

SELECTED WORK

Research Project

From foundation policies
to real-world adaptation.

PARTS2026
Earbud insertion · Autonomous 2×
Real-world robot learning2026

PARTS

From Pretraining to Proficiency: Real-World Subtask RL for Long-Horizon Manipulation with Minimal Human Intervention

Sichang Su, Benjamin Yang, Zhiyun Deng, Boyuan Liang, Yip Fun Yeung, Zelin Wang, and Lingfeng Sun

PARTS concentrates real-world reinforcement learning on the bottleneck subtasks of long-horizon manipulation. Lightweight residual policies adapt a frozen base policy while reusing its reliable behaviors, improving complete-task performance without human action corrections during rollouts.
ReinFlow2025
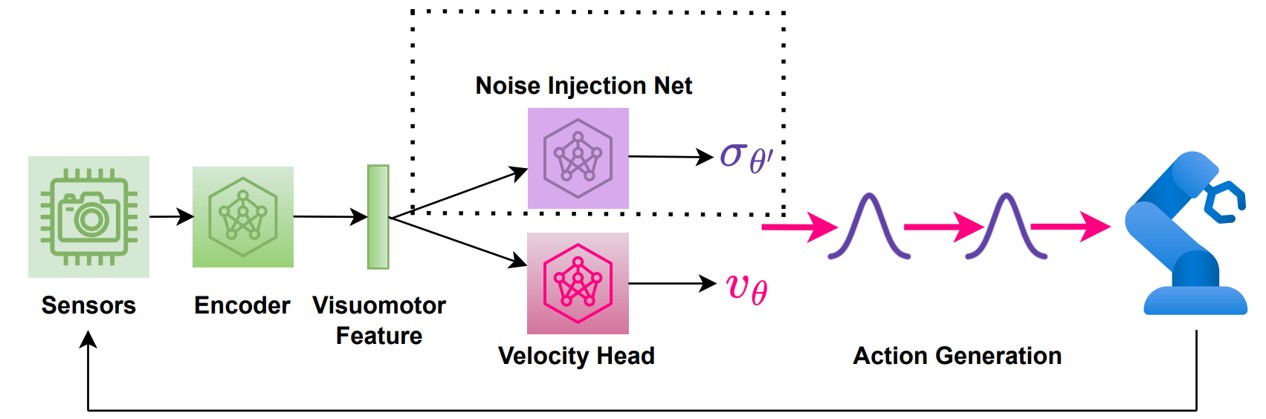
ReinFlow architecture: visual features feed a velocity head and a learned noise-injection network to generate robot actions during online reinforcement learning. NeurIPS 2025
NeurIPS 20252025

ReinFlow

ReinFlow: Fine-tuning Flow Matching Policy with Online Reinforcement Learning

Tonghe Zhang, Chao Yu, Sichang Su, and Yu Wang

ReinFlow fine-tunes pretrained flow-matching policies with online reinforcement learning. A learned noise-injection network enables exploration and tractable policy likelihoods during training, while preserving efficient deterministic flow inference after fine-tuning.

RESEARCH IN PRACTICE

Industry Experience

May–August 2026

Boston, United States

AUTEL US Inc.

Research Intern

Mentor: Dr. Lingfeng Sun

  • Developed real-world reinforcement learning post-training for vision-language-action models on YAM and Franka robots for long-horizon manipulation.
  • Built supervised fine-tuning and inference pipelines for UMI data and collected GELLO teleoperation demonstrations. GitHub
  • Developed a VLM-driven subtask annotator for LeRobot datasets with human verification.
  • Developed an end-to-end RECAP (RL with Experience and Corrections via Advantage-conditioned Policies) pipeline on YAM bimanual arms. GitHub

March–July 2025

Beijing, China

D-Robotics

Research Intern

Mentor: Dr. Chao Yu

  • Investigated online reinforcement learning post-training for generative robot policies, including flow-matching models.
  • Built articulated manipulation environments in SAPIEN, collected expert demonstrations, and trained diffusion policies for multi-task manipulation.
  • Implemented LoRA fine-tuning for OpenVLA-OFT, π₀, and π₀-FAST on LIBERO.

GET IN TOUCH

Let’s talk research.

I welcome conversations about robot learning,
research collaborations, and related opportunities.

sichang_su@utexas.edu