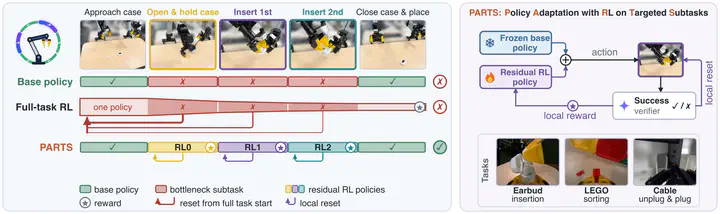
PARTS
From Pretraining to Proficiency: Real-World Subtask RL for Long-Horizon Manipulation with Minimal Human Intervention
Sichang Su
Ph.D. student (Mechanical Engineering from Spring 2027)
I study reinforcement learning and robotics, with a focus on efficiently adapting robot foundation models to out-of-distribution tasks with minimal human supervision.